Guolin Yang
Robotics & Autonomous Systems
Hi there! I’m a PhD Researcher in Robotics and AI / Control Systems and Robotics at the University of Manchester, advised by Prof. Guido Herrmann and Prof. Alessandra Parisio. I am also mentored by Dr. Anthony Siming Chen. I expect to complete my PhD in December 2026. Before my PhD, I worked on ADAS software at Lotus Technology and battery-management-system software and validation at NIO.
My research interests include World Models, Model-Based Reinforcement Learning, Motion Planning, Model Predictive Control, and Safe Control. I build predictive autonomous systems that reason about action-dependent future interactions and make real-time decisions in dynamic multi-agent environments.
My recent work includes interaction-aware latent world models for crowd navigation, uncertainty-aware MPPI with CBF/CVaR safety mechanisms, and real-time multi-obstacle safety filtering. Across the reported studies, the best evaluated configuration reached 99.9% navigation success, improved OOD success by 4.8 percentage points, and reduced collision rate from 7.8% to 3.8% with a 9.30 ms safety-filter runtime.
Recent News
| Sep 2026 | Presented Risk-Bounded Predictive Control for Automated Vehicles in Shared-Space Areas at AVEC 2026 in Tsukuba, Japan. |
|---|---|
| 2026 | A Safety Framework for Uncertainty-Aware Model Predictive Path Integral Control in Shared-Space Navigation accepted to IEEE CDC 2026. |
| 2026 | PIP-CN: Prediction-Integrated Planning for Crowd Navigation accepted to IEEE/RSJ IROS 2026. |
| 2025 | Co-authored work on intelligent industrial PV-panel cleaning recommendation published in Applied Energy. |
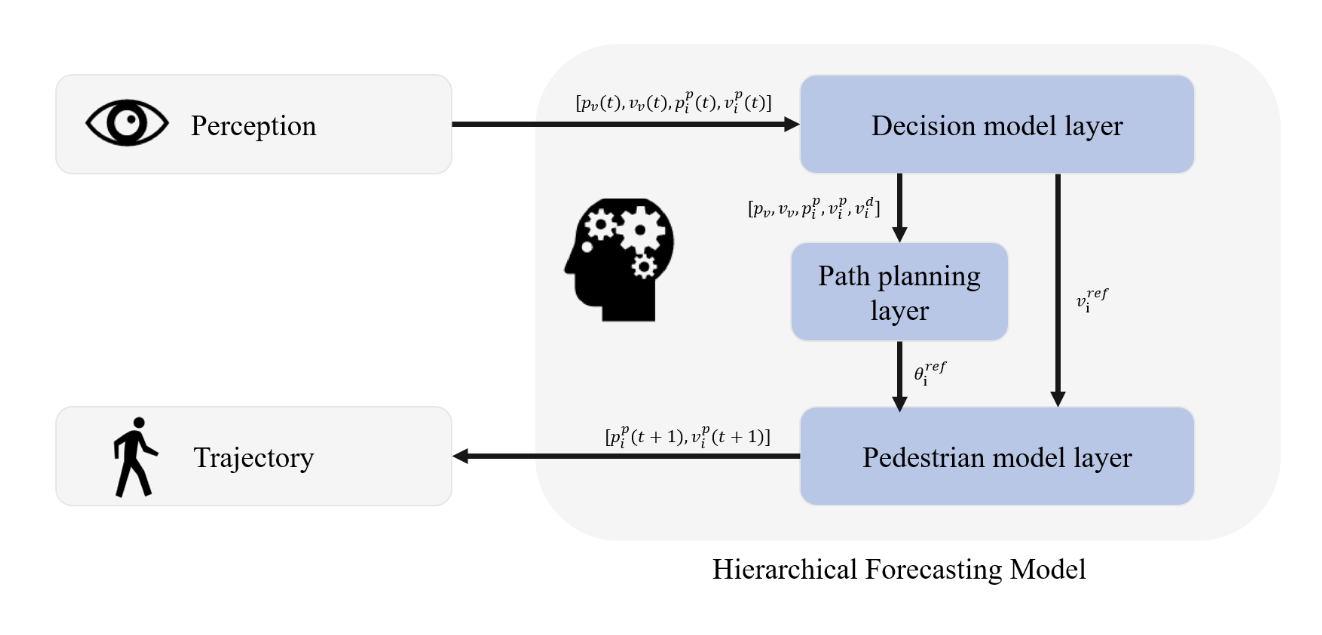
| 2024 | A Hierarchical Forecasting Model of Pedestrian Crossing Behaviour for Autonomous Vehicle published in IEEE Access. |
Selected Projects
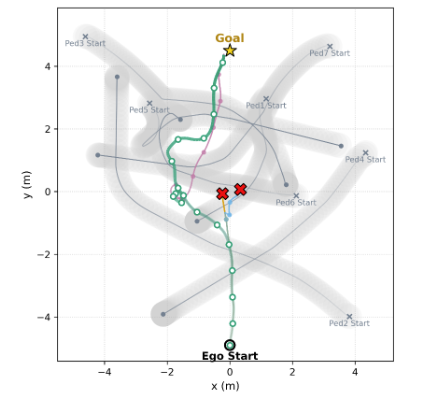
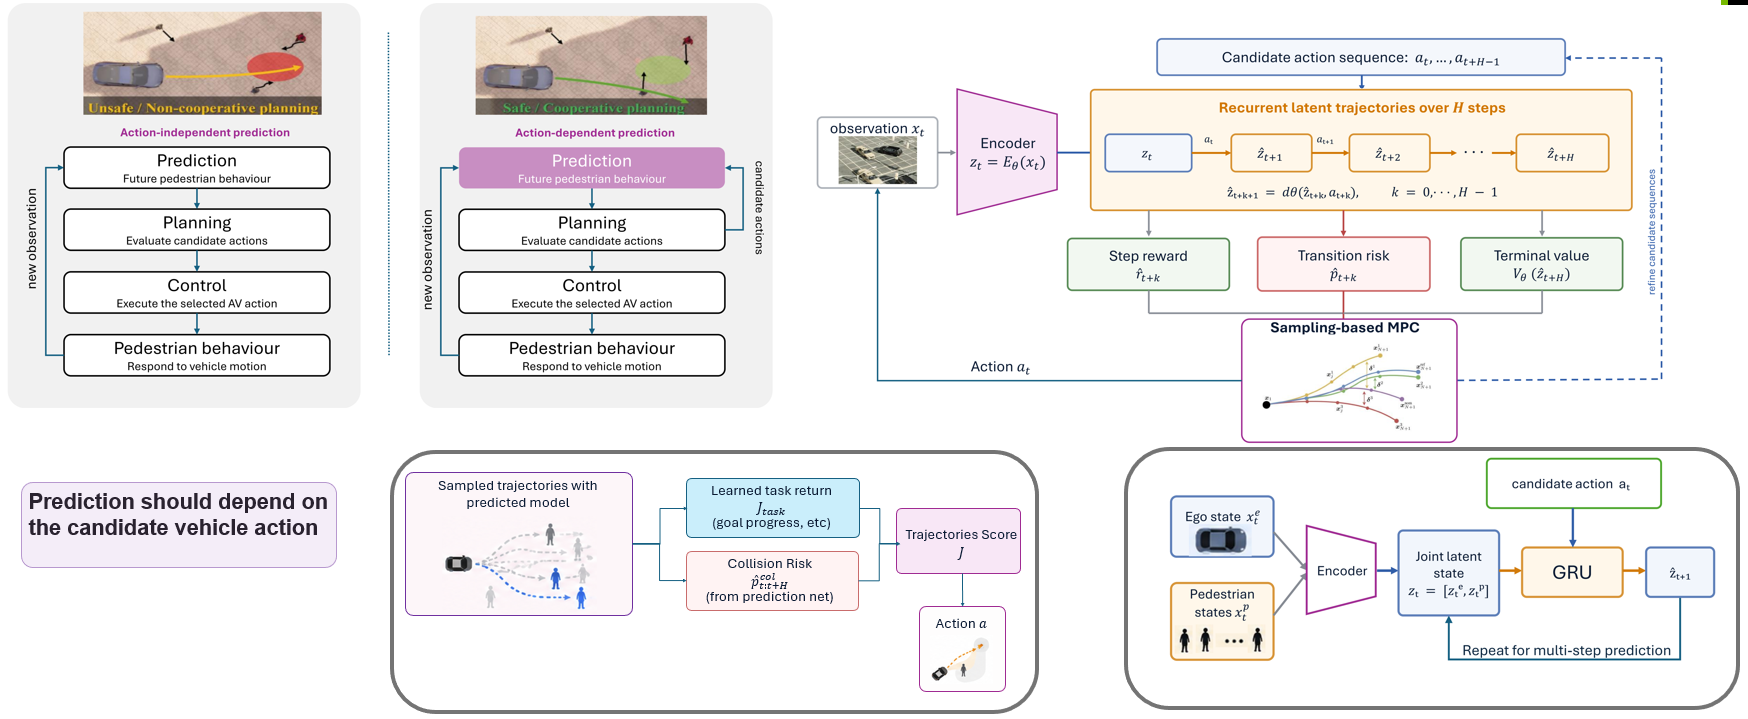
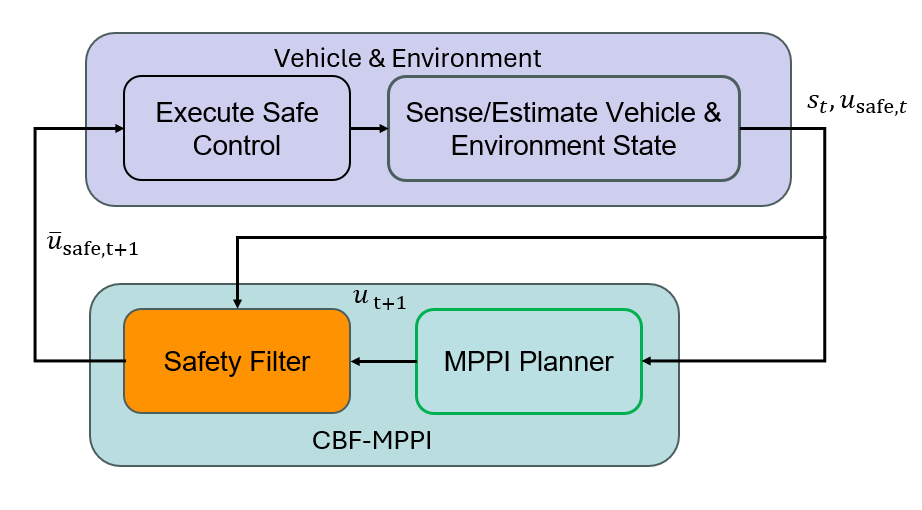
Research: world models · model-based RL · MPPI/MPC · motion planning · CBF · CVaR · autonomous systems.